TC7-R5 7-Axis Full Force-Controlled Arm × Quadruped Robot: Automated Train Undercarriage Inspection
2026-08-20
1. Project Background
Urban rail networks are expanding rapidly worldwide, and the undercarriage maintenance of rolling stock has become one of the most labor-intensive tasks in rail operations. As train fleets grow, metro and light-rail operators face a widening shortage of skilled inspection personnel. Manual undercarriage inspection is difficult to sustain at scale, and operators urgently need an automated, intelligent solution that safeguards inspection quality while dramatically improving efficiency and freeing up experienced technicians.
2. The Inspection Challenge
Undercarriage inspection is a high-intensity, repetitive job performed in a harsh environment. Inspection pits are typically about 1.5 m deep and 1.1 m wide, forcing technicians into prolonged stooping and head-tilted postures that cause fatigue and ergonomic strain.
A single trainset typically carries 200+ undercarriage inspection points distributed beneath the vehicle—across the bogie, braking system, traction system, and coupler buffer assembly—each of which must be checked individually. Manual visual inspection of one trainset takes 2–3 hours, and detection quality fluctuates with operator fatigue.
Earlier inspection robots on the market mostly paired an AGV chassis with a 6-axis arm. In the cramped, pipe-dense space beneath a train, the 6-axis arm suffers severe kinematic interference—many positions are physically unreachable or impossible to navigate around. Camera angles are limited, leaving numerous inspection points partially or fully obscured and creating persistent visual blind spots.
3. The Solution: Quadruped Robot + TC7-R5
Techrobots' TC7-R5 7-axis full force-controlled humanoid robot arm is bringing flexible, high-efficiency intelligent visual inspection to a growing range of rail-transit scenarios. This solution adopts a “quadruped robot + TC7-R5” architecture that decouples mobility from observation—each component does what it does best.
3.1 The Quadruped Robot Handles “Reaching”
Its four-legged gait is inherently suited to complex terrain such as steps, slopes, and track switches. It can autonomously navigate into the inspection pit and hold position steadily at the assigned stall. Compared with wheeled AGVs, the quadruped is not constrained by rails, moving flexibly between switch zones and multiple tracks, which significantly improves reach coverage.
3.2 The TC7-R5 Handles “Seeing”—the Core of the Solution
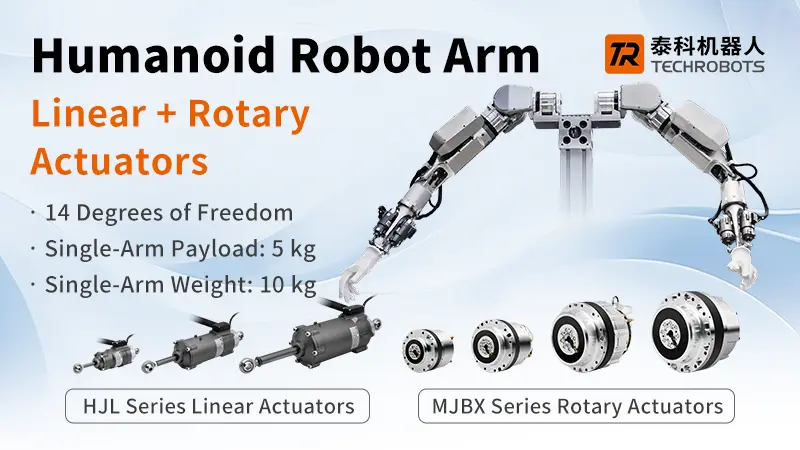
The TC7-R5 is built with 7 rotary joints. Its 7-DOF (seven degrees of freedom) configuration lets it assume a wide variety of human-arm-like poses, giving it stronger spatial adaptability and more complete inspection coverage. In pipe-dense areas it can fold its arm inward to reach in, routing around obstacles such as brake lines and air lines to aim the camera precisely at every inspection point. As a full force-controlled humanoid arm, it also gains smarter autonomous operation and safer Human-Robot Interaction (HRI). Where a conventional 6-axis arm cannot reach or see, the extra degree of freedom of the 7-axis arm “bends around” the obstruction—resolving kinematic interference and sharply reducing blind spots.
At the end effector, an HD camera and a 3D vision module capture multi-angle, high-resolution images and build 3D models of defects such as bogie cracks, loose bolts, fluid leakage, and cable degradation. Combined with AI vision recognition algorithms, anomalies are flagged in real time, delivering detection accuracy and coverage far beyond fixed-viewpoint solutions.
On the control side, the TC7-R5 can run an embodied-intelligence “cerebellum” control system that supports complex motion planning with millisecond-level command response. For communication it supports EtherCAT or CANopen real-time fieldbuses and exposes low-level secondary-development interfaces (SDK), making it easy for integrators to connect with existing inspection systems.
4. Application Results
The inspection workflow is highly automated end to end: the quadruped autonomously navigates into position → the TC7-R5 7-axis arm deploys into its inspection pose → multi-angle visual inspection of each point → HD images plus 3D point-cloud data acquisition → AI recognition generates the report, with no manual intervention required.
The solution covers 200+ inspection points across the bogie, braking system, traction system, and coupler buffer assembly. Field deployment data shows:
Single-trainset inspection time drops from 120 minutes to 20 minutes—about an 83% efficiency gain.
Night-shift labor can be reduced by 37.5%, effectively easing workforce shortages.
Fault recognition rate reaches 98.1%, far exceeding manual visual inspection.
Defect identification accuracy reaches up to 99%, and per-component inspection time is cut by 70% versus manual methods.

5. TC7-R5 Key Specifications
| Item | Specification |
| Configuration | 7 rotary actuator (7-DOF) |
| Single-arm weight | 12kg |
| Single-arm payload | ≥5kg |
| Single-arm reach | 600mm |
| Joint actuator | MJBX series (Axes 1–2: MJB20T / Axes 3–4: MJB17T / Axes 5–7: MJB14T) |
| Force sensors | Optional single-axis force sensor per joint |
| Brakes | Permanent-magnet brakes on all joints |
| Communication | EtherCAT / CANopen |
| Vision | HD camera and 3D vision module at the end effector (Optional) |
"The TC7-R5 seven-axis full force-controlled humanoid arm paired with a quadruped robot redefines train undercarriage inspection: by decoupling mobility from observation, the extra degree of freedom eliminates the kinematic blind spots that limit conventional 6-axis arms, delivering 200+ point coverage, 83% faster cycles, and 98.1% fault detection. This turnkey architecture is ideal for rail operators and system integrators building the next generation of automated, AI-driven rolling-stock maintenance."
Previous Article: None
Next Article: 1.8-Meter Arm Span, 20kg High Load Palletizing Robot